Rate of Growth in regards with input of n (Big Order of growth notation): Asymptotically Tight Bound (Θ) : Big O(Θ) is noted to give us the upper (max) bound (worst case scenario , with the largest constant k1) and a lower (min) bound (best case scenrio) as well withContinue Reading

An invertible matrix must be a square matrix: The formula is:   B = A−1 Non-square matrices (m-by-n matrices for which m ≠ n}}) do not have an inverse, but can in sometimes have a left inverse or right inverse.Continue Reading

A heuristic technique is not guaranteed to be optimal, but which is nevertheless sufficient for reaching an immediate, short-term goal, with a satisfactory solution. Examples of such: Trial and error, Rule of thumb, Educated guess, Intuitive judgment, Guesstimate, Profiling, Common sense. More concrete examples are: * Sorting and prioritizing isContinue Reading

The friction force is the force exerted by a surface when an object exerts force across it.   A coefficient of friction(μ) is a scalar proportion of two objects and their normal reaction. There are 2 cases: Is the dynamic/kinetic coefficient of friction when either or both objects are dynamic. IsContinue Reading

The relationship between body, forces acting upon it, and its motion. In an inertial frame of reference is when net force is equal to zero = therefore there is no resistance to the object’s velocity. First law: In an inertial frame of reference, an object either remains at rest orContinue Reading

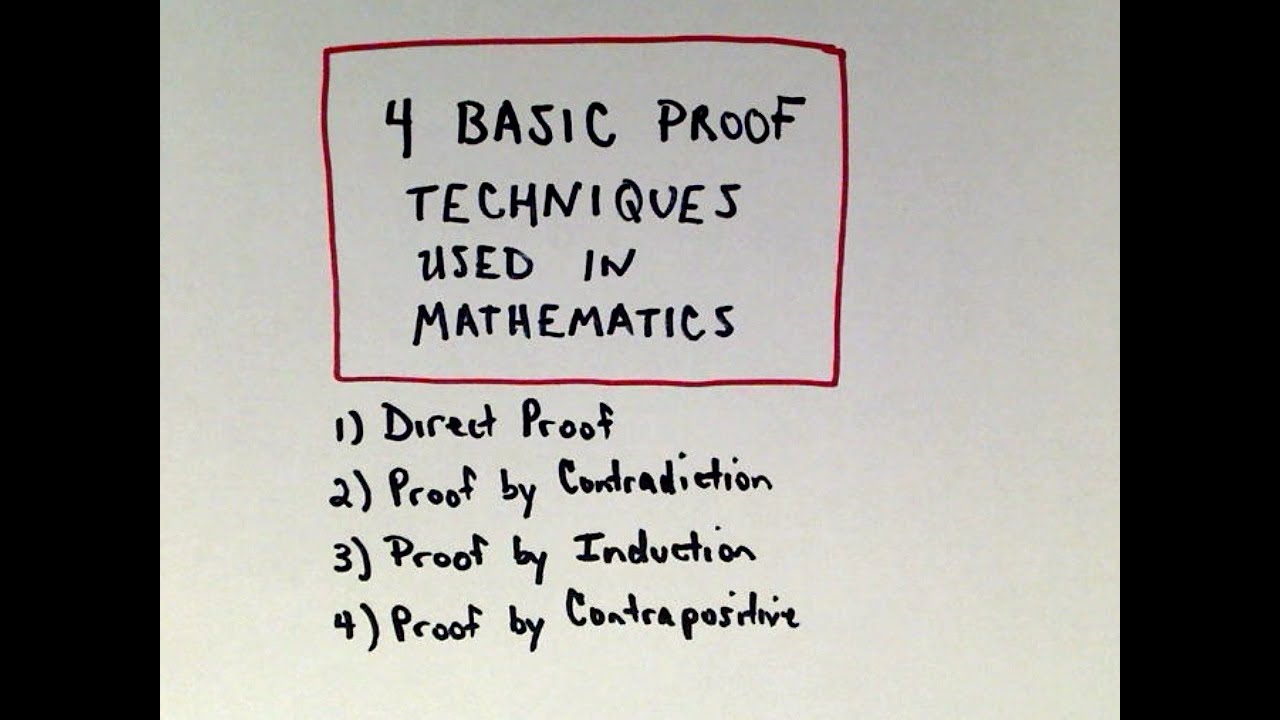
Property P(n) holds for every natural number n(0….N) or every between (x∈N…N) The method of induction requires two cases to be proved. The base case (or, sometimes, the basis), proves that the property holds for the number 0. (This is easy to compute and check for the number n). TheContinue Reading

Repetition and mapping tables for lossless(like RLE,LZ77-8,Huffman algorithms), or for lossy(discrete cosine transform (DCT) waves interpolation or chroma-based algorithms), are the basis of fewer bytes compression. This can produce overhead in non-repeatable/differentiable files, and even in cases of lossy files when the loss accepted is small. If the application isContinue Reading

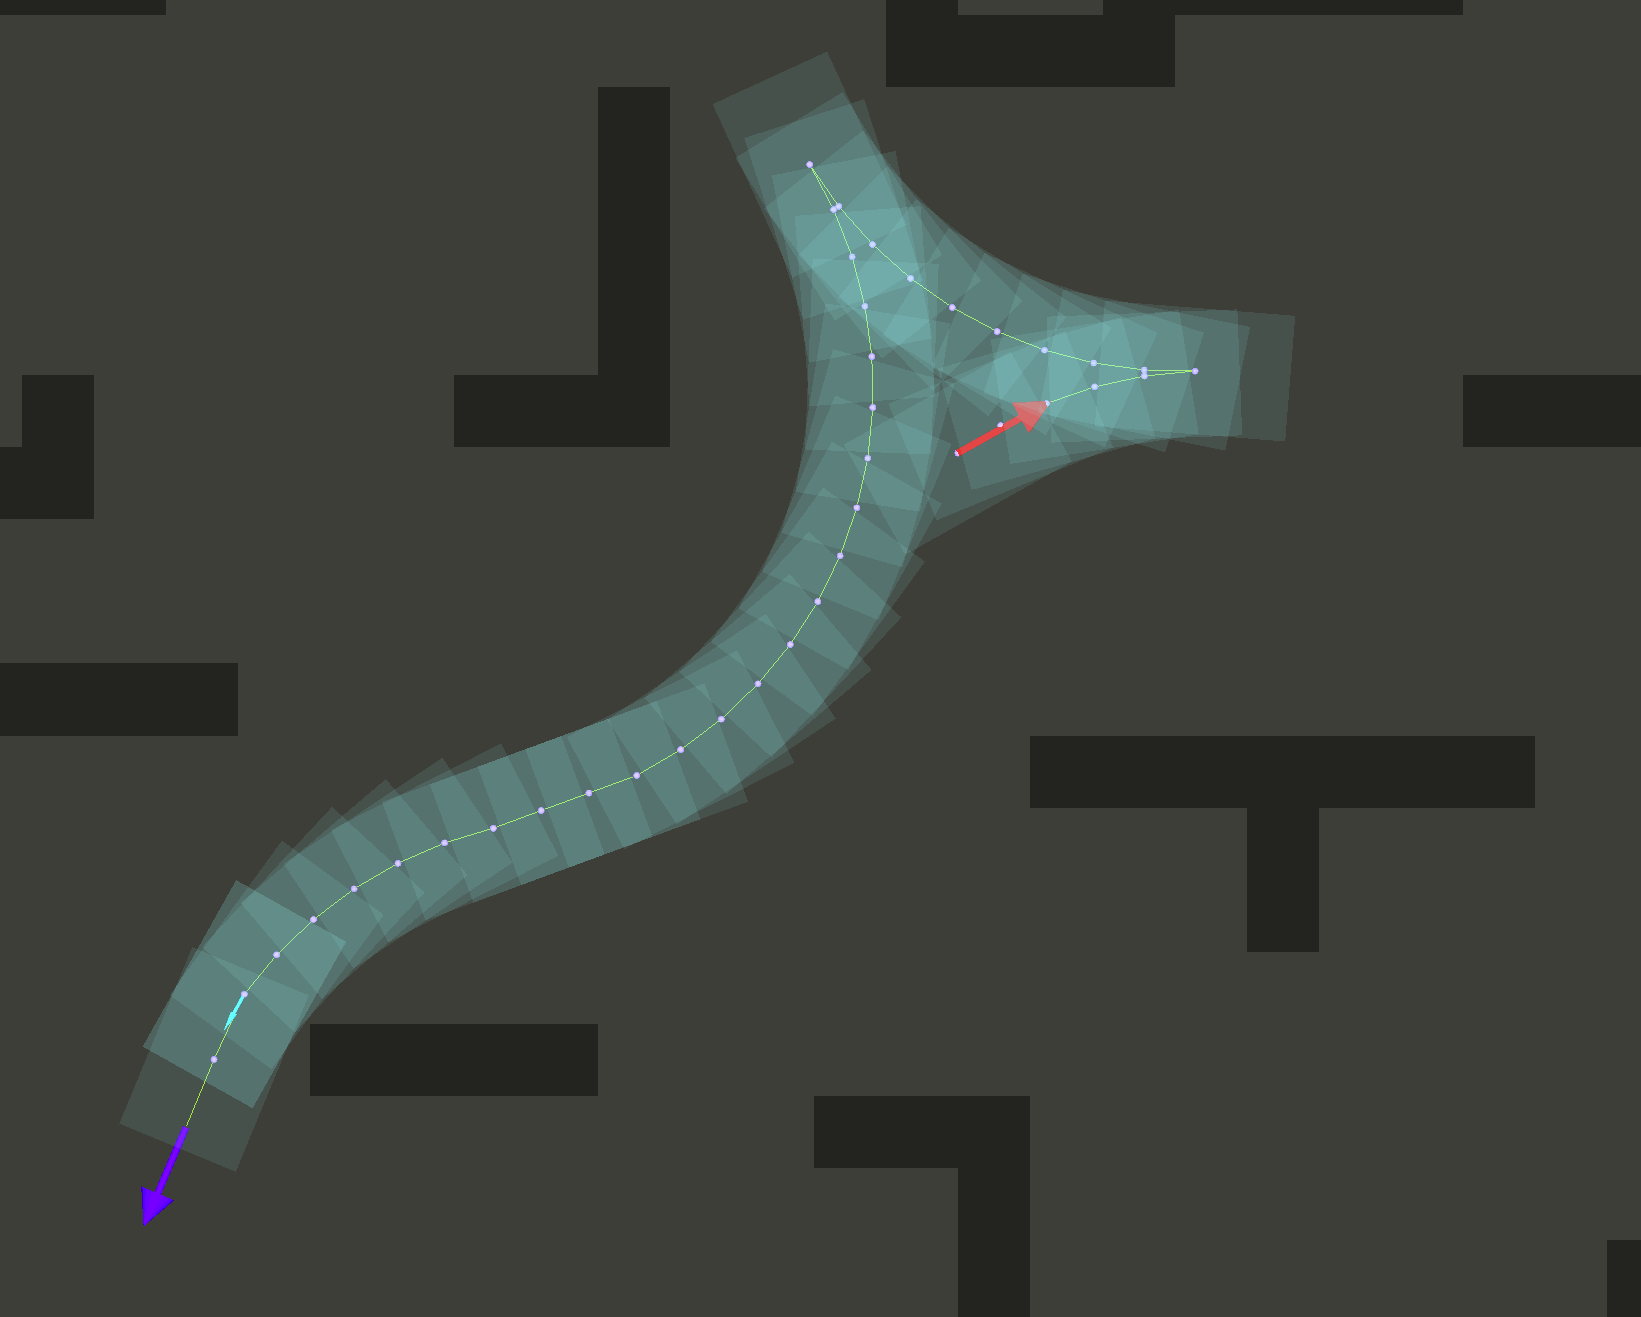
Hybrid A* is a function that differs from A* by the fact that it is continuous but isn’t complete, that is, it can’t always find an optimal solution or a solution, but every solution that it does find is continuous and constrain-able.Continue Reading

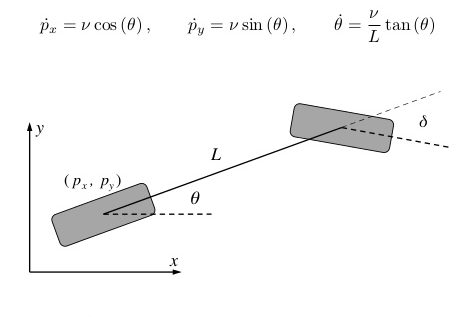
MPC is used to optimize control inputs by approximating a reference trajectory using dt, N and T variables in a finite(2-3 seconds) time-horizon. This reference trajectory should encompass very small values of dt which will be multiplied by N (should be a number that when multiplied by dt is 2-3Continue Reading