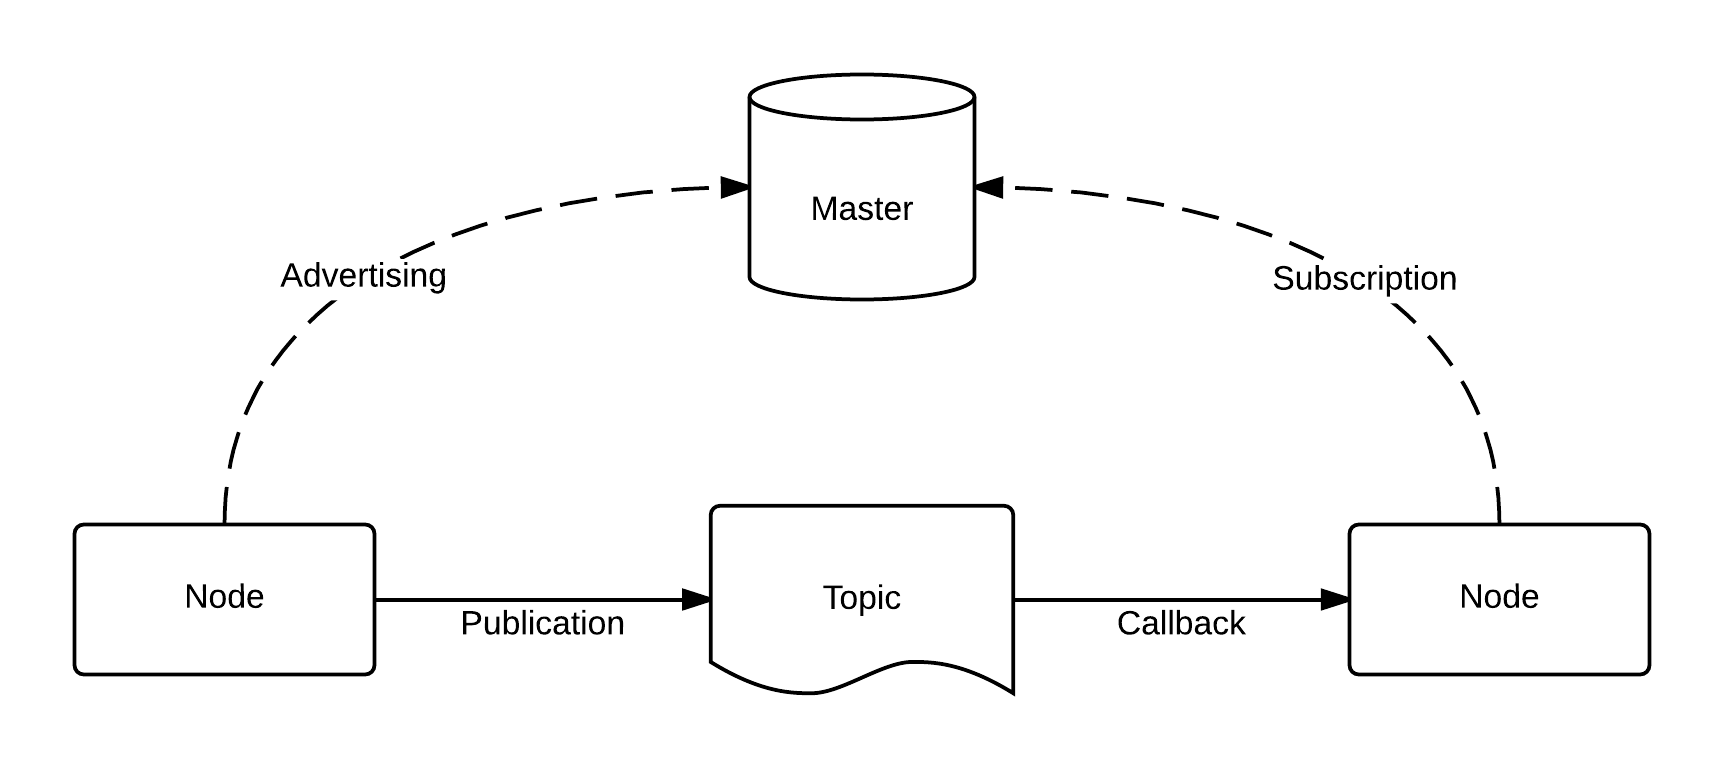
The following two functions should be launched in two separate python threads. They show how easy ROS enables to create a pub/sub relationship for transferring messages between nodes. sub.py *import rospy* from std_msgs.msg import String def talker(): pub = rospy.Publisher(‘chatter’, String, queue_size=10) rospy.init_node(‘talker’, anonymous=True) rate = rospy.Rate(10) # 10hz whileContinue Reading

Determine whether an integer is a palindrome. An integer is a palindrome when it reads the same backward as forward. Example 1: Input: 121 Output: true Example 2: Input: -121 Output: false Explanation: From left to right, it reads -121. From right to left, it becomes 121-. Therefore it is not a palindrome. ExampleContinue Reading

Tensorflow

After training we can optimize a frozen graph or even a dynamic graph by removes training-specific and debug-specific nodes, fusing common operations, and removes code that isn’t used/reached. Code Example from tensorflow.python.tools import optimize_for_inference_lib inputGraph = tf.GraphDef() #read in a frozen model with tf.gfile.Open(‘frozentensorflowModel.pb’, “rb”) as f: data2read = f.read() inputGraph.ParseFromString(data2read) outputGraph = optimize_for_inference_lib.optimize_for_inference(inputGraph, [“inputTensor”],        Continue Reading

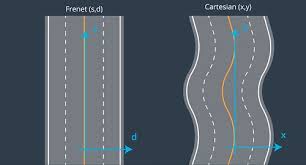
Frenet coordinates are an alternative way to describe a curve in 2D space, this most commonly can be useful while computing displacement of a vehicle’s position on the road or a calculating it’s reference path. The Frenet coordinates is composed of two coordinates. s coordinate – representing distance along theContinue Reading